Technology
Learn about the platform powering today's most advanced automation applications


Technology
Learn about the platform powering today's most advanced automation applications
Technology
Learn about the platform powering today's most advanced automation applications

Fleet Coordination
Fleet Coordination
Coordinate your entire mobile robot fleet from one intelligent platform
Coordinate your entire mobile robot fleet from one intelligent platform
Keep your fleet moving intelligently
Keep your fleet moving intelligently
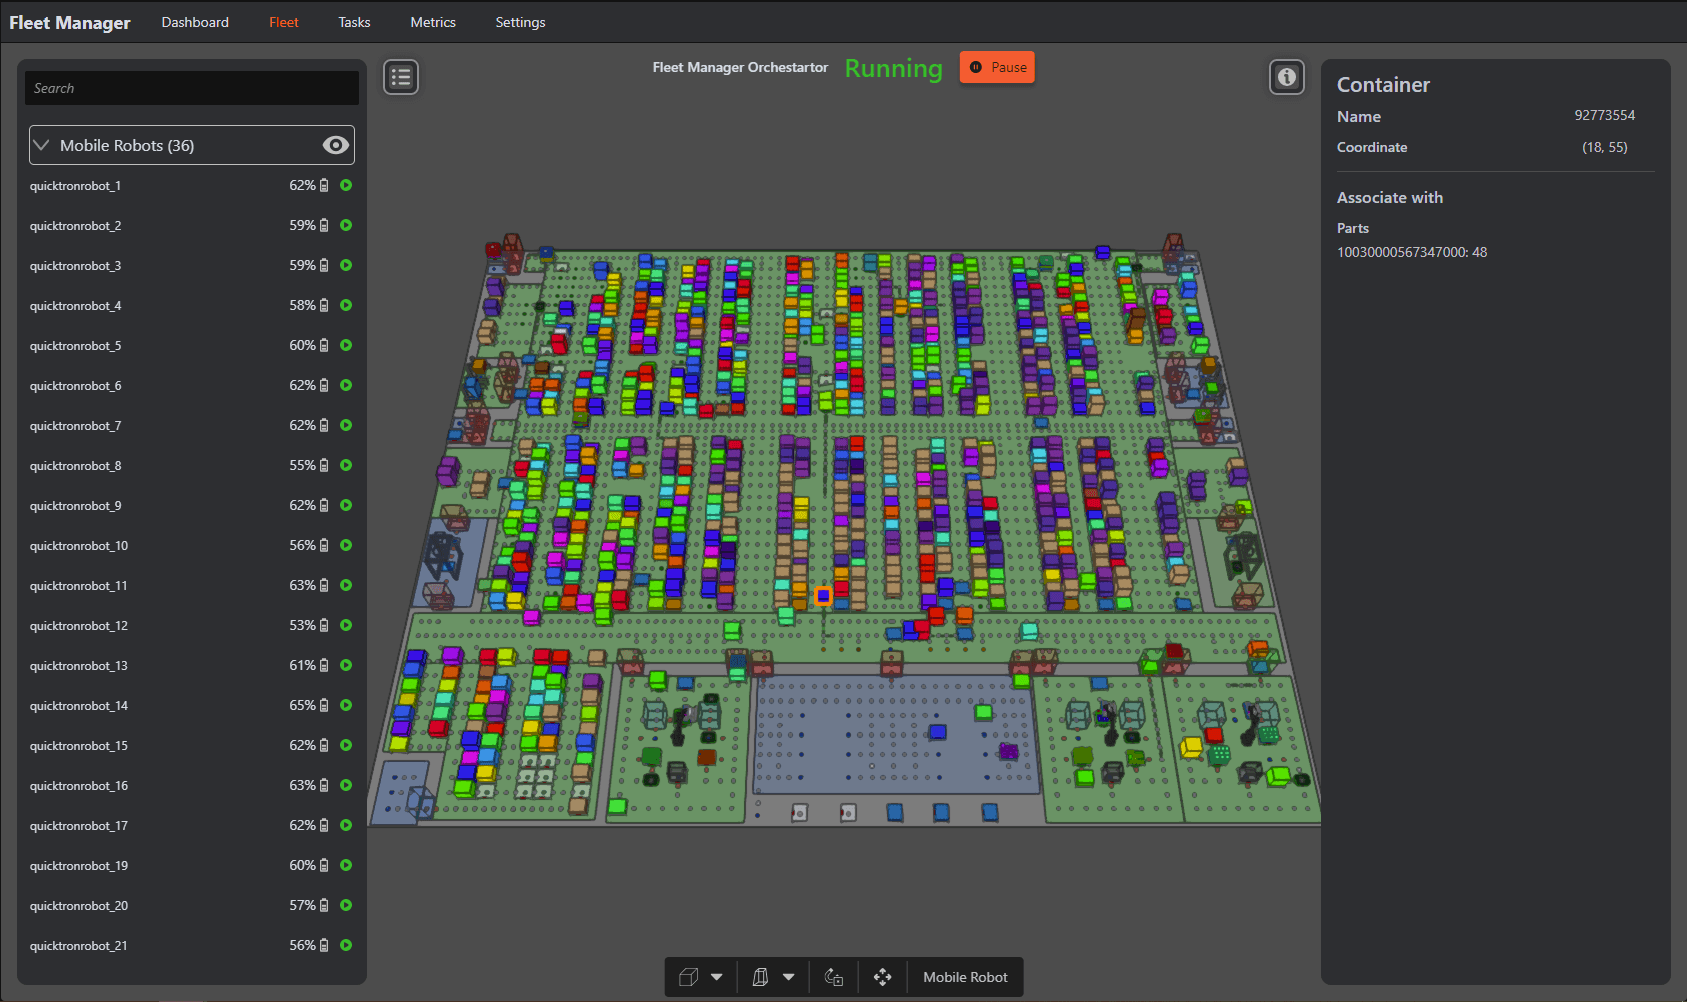
MujinOS continuously allocates tasks, plans routes, and coordinates robot movements in real time. As priorities and operating conditions change, the fleet adapts automatically to keep material moving efficiently.
MujinOS continuously allocates tasks, plans routes, and coordinates robot movements in real time. As priorities and operating conditions change, the fleet adapts automatically to keep material moving efficiently.

Dynamic Task Allocation
Continuously assign and reprioritize transport tasks based on operational needs
Dynamic Task Allocation
Continuously assign and reprioritize transport tasks based on operational needs
Coordinated Path Planning
Plan robot movements across the fleet to reduce congestion, conflicts, and unnecessary waiting
Continuous Replanning
Adapt routes and execution in real time as conditions and priorities change
Continuous Replanning
Adapt routes and execution in real time as conditions and priorities change
Multi-Vendor Fleet Control
Coordinate AGVs and AMRs from different manufacturers through one intelligent control layer

Simple map building and editing
Simple map building and editing
Build and manage large-scale maps with complex obstacles and interactions. The integrated map editor updates AGV and AMR routing instantly, enabling on-the-fly changes and scalable deployment.
Build and manage large-scale maps with complex obstacles and interactions. The integrated map editor updates AGV and AMR routing instantly, enabling on-the-fly changes and scalable deployment.
Executed by MujinOS
Executed by MujinOS
The execution layer receives goals from higher-level systems and orchestrates tasks across mobile robots, enabling application-specific priorities, smooth interaction with surrounding systems, and coordination with on-site operations for stable, predictable performance.
Case study
See MujinOS in action
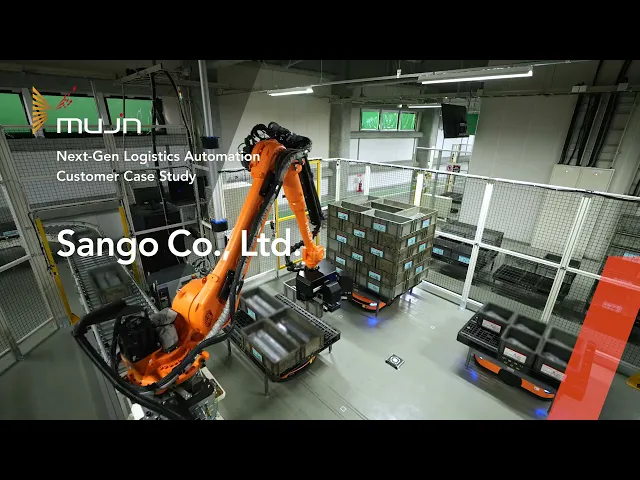
An automotive parts manufacturer transformed its factory logistics into a fully automated in-factory warehouse operation with MujinOS, orchestrating depalletizing robots, AGVs, and warehouse systems as one connected flow. The result: 67% less manual handling labor, 2,080 fewer truck trips annually, and a smarter, more sustainable logistics operation.
Have a question?
Learn how MujinOS delivers real-time perception, motion control, and no-code deployment—across any robotic system
Have a question?
Learn how MujinOS delivers real-time perception, motion control, and no-code deployment—across any robotic system
Have a question?
Learn how MujinOS delivers real-time perception, motion control, and no-code deployment—across any robotic system